Cristian C. Beltran-Hernandez

OMRON SINIC X Corporation | Senior Researcher

prof_pic_small.png

I am a Senior Researcher at OMRON SINIC X, working on robot learning for contact-rich manipulation — the moments where a robot stops moving freely and starts pushing, inserting, or cutting. That transition is where most real manipulation tasks get hard, and it runs through everything from industrial assembly to cooking.

My work follows three threads. The first is learning force and compliance control on position-controlled robots: variable compliance for peg-in-hole assembly, hybrid trajectory-and-force learning to imitate human assembly skills, and more recently diffusion policies for compliant manipulation. The second is soft robotics and tactile sensing, where mechanical compliance and touch make insertion, scooping, and fine powder handling robust to uncertainty that rigid systems handle poorly. The third is vision-language-guided task and motion planning, turning long-horizon instructions into executable plans for assembly and food preparation.

Some of this work has traveled beyond the lab. Our robot food-slicing framework, SliceIt!, was featured by IEEE Spectrum, and the assembly system I helped build with Team O2AC took 3rd place and a JSAI special award at the World Robot Summit 2020 Industrial Assembly Challenge.

I received my Ph.D. in engineering (2022) and M.Eng. in intelligent systems (2019) from The University of Osaka, and my B.Sc. in computer science from the University of La Sabana, Colombia (2013).

news

Sep 15, 2026 We have two papers accepted to CoRL 2026!:
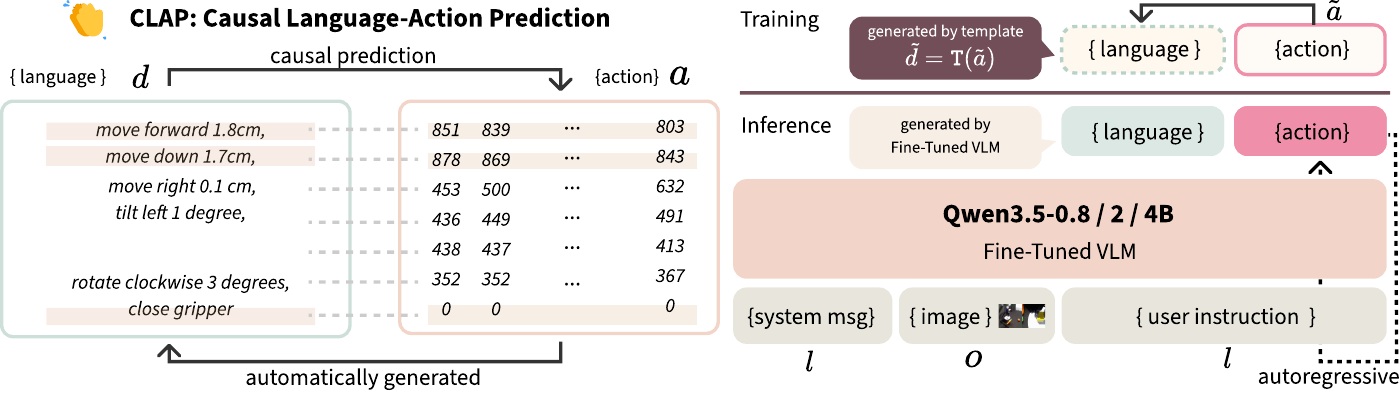
  • CLAP: Direct VLM-to-VLA Adaptation via Language-Action Grounding Yuri Ishitoya, Jeremy Siburian, Masashi Hamaya, Haruto Suzuki, Kuniaki Saito, Toshihiko Fukushima, Cristian Camilo Beltran-Hernandez, Mai Nishimura
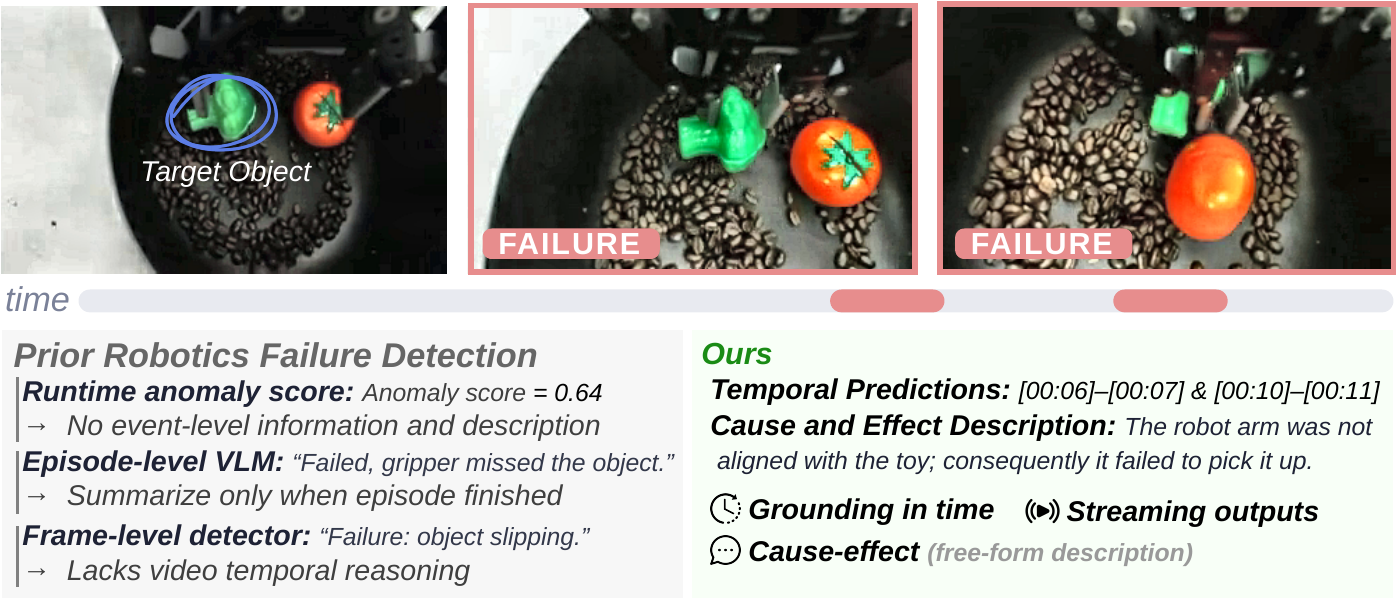
  • Online Robot Manipulation Error Detection and Description Yung-Shun Chan, Kuniaki Saito, Cristian Camilo Beltran-Hernandez, Jeremy Siburian, Masashi Hamaya, Chun-Yi Lee
Jun 17, 2026 We have two papers accepted to IROS 2026!:
  • Grounded Vision-Language Interpreter for Long-Horizon Bimanual Task and Motion Planning Jeremy Siburian, Keisuke Shirai, Cristian Camilo Beltran-Hernandez, Masashi Hamaya, Michael Görner, Atsushi Hashimoto
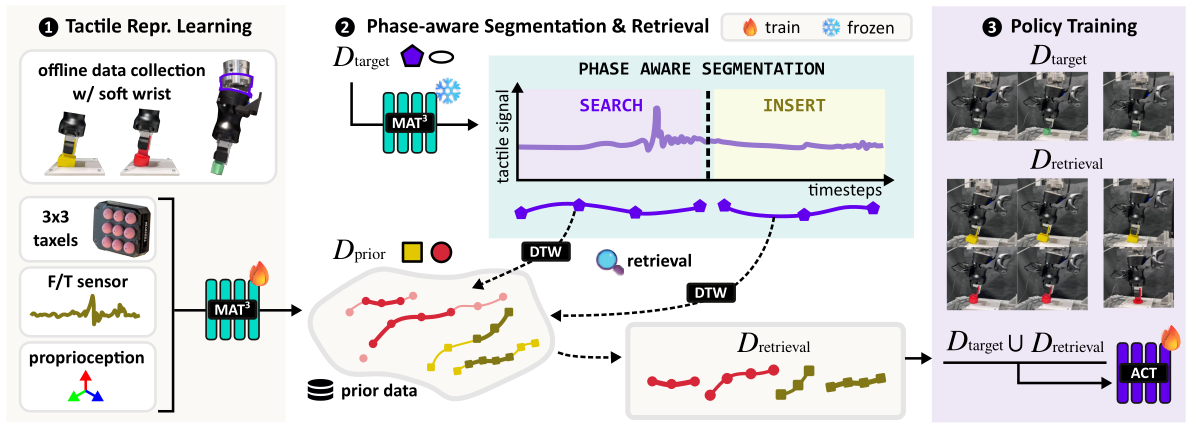
  • PHASE: Compliance-Enabled Tactile Phase Retrieval for Few-Shot Insertion Learning Jeremy Siburian, Cristian Camilo Beltran-Hernandez, Tatsuya Matsushima, Yusuke Iwasawa, Masashi Hamaya, Mai Nishimura
Jun 01, 2026 We got two papers were accepted to the journal of Robotics and Automation Letters!
  • Tactile Memory with Soft Robot: Robust Object Insertion via Masked Encoding and Soft Wrist Tatsuya Kamijo, Mai Nishimura, Nodoka Shibasaki, Jeremy Siburian, Cristian C. Beltran-Hernandez, Masashi Hamaya
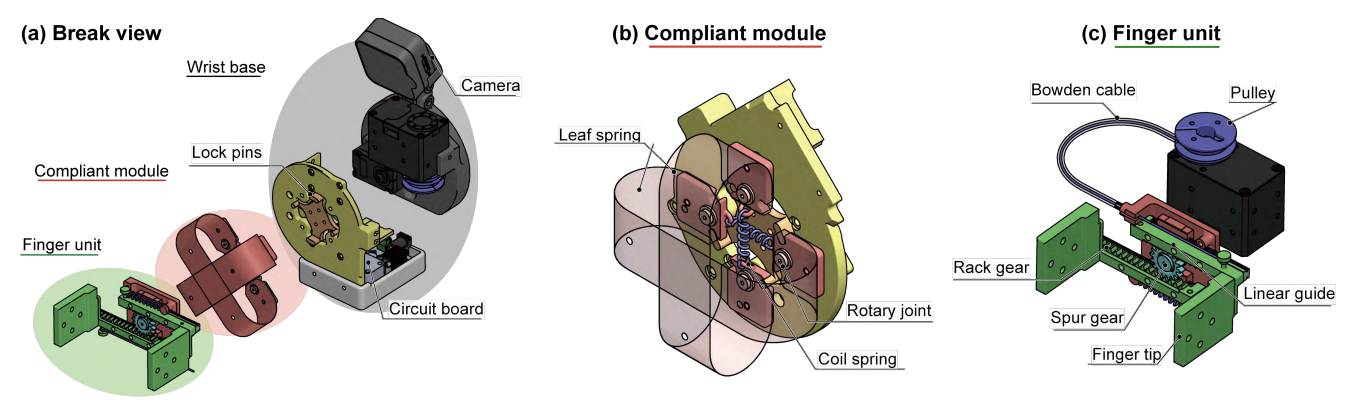
  • A Flexible Wrist with Anisotropic and Selectable Stiffness for Robust Contact-Rich Manipulation Steven Oh, Tomoya Takahashi, Cristian C. Beltran-Hernandez, Yuki Kuroda, Masashi Hamaya
Feb 01, 2026 We have three papers accepted to ICRA 2026!:
  • Robust and Resilient Soft Robotic Object Insertion with Compliance-Enabled Contact Formation and Failure Recovery
  • Simulation-Driven Evolutionary Motion Parameterization for Contact-Rich Granular Scooping with a Soft Conical Robotic Hand
  • A Flexible Funnel-Shaped Robotic Hand with an Integrated Single-Sheet Valve for Milligram-Scale Powder Handling

selected publications

  1. CoRL
    clap2026.png
    CLAP: Direct VLM-to-VLA Adaptation via Language-Action Grounding
    Yuri Ishitoya, Jeremy Siburian, Masashi Hamaya, Haruto Suzuki, Kuniaki Saito, and 3 more authors
    In Conference on Robot Learning (CoRL), 2026
  2. CoRL
    error_detect_elsa_teaser.png
    Online Robot Manipulation Error Detection and Description
    Yung-Shun Chan, Kuniaki Saito, Cristian C. Beltran-Hernandez, Jeremy Siburian, Masashi Hamaya, and 1 more author
    In Conference on Robot Learning (CoRL), 2026
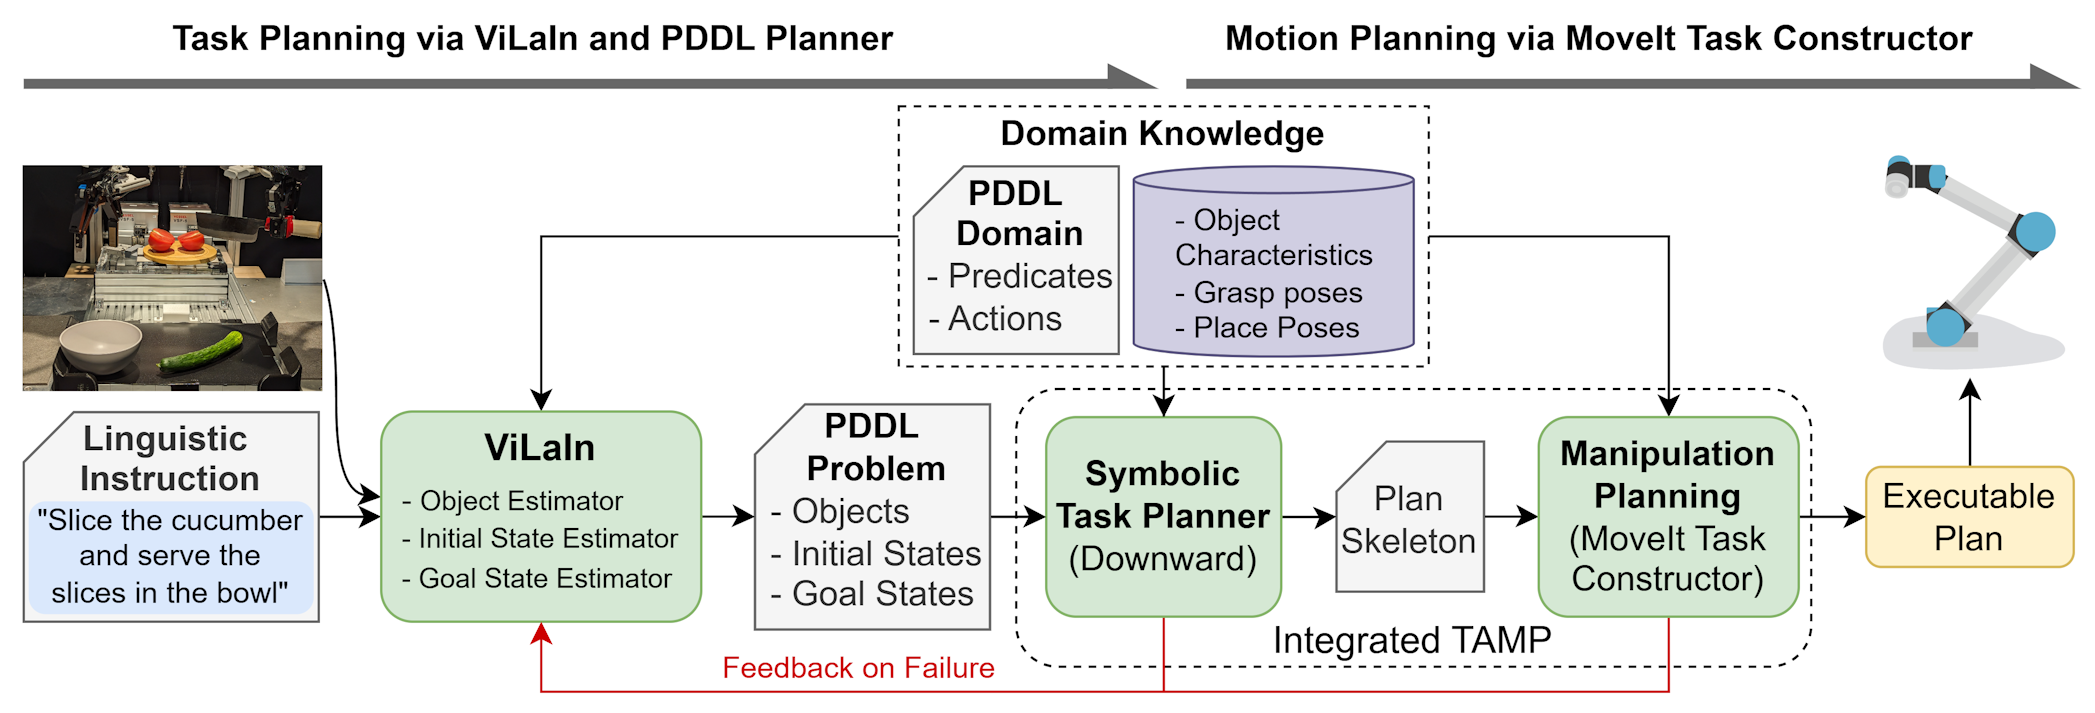
  3. Grounded Vision-Language Interpreter for Integrated Task and Motion Planning
    Cristian C. Beltran-Hernandez, Jeremy Siburian, Keisuke Shirai, Masashi Hamaya, Michael Görner, and 1 more author
    2026
  4. PHASE: Compliance-Enabled Tactile Phase Retrieval for Few-Shot Insertion Learning
    Jeremy Siburian, Cristian C. Beltran-Hernandez, Tatsuya Matsushima, Yusuke Iwasawa, Masashi Hamaya, and 1 more author
    2026
  5. A Flexible Wrist With Anisotropic and Selectable Stiffness for Robust Contact-Rich Manipulation
    Steven Oh, Tomoya Takahashi, Cristian C. Beltran-Hernandez, Yuki Kuroda, and Masashi Hamaya
    IEEE Robotics and Automation Letters, Aug 2026
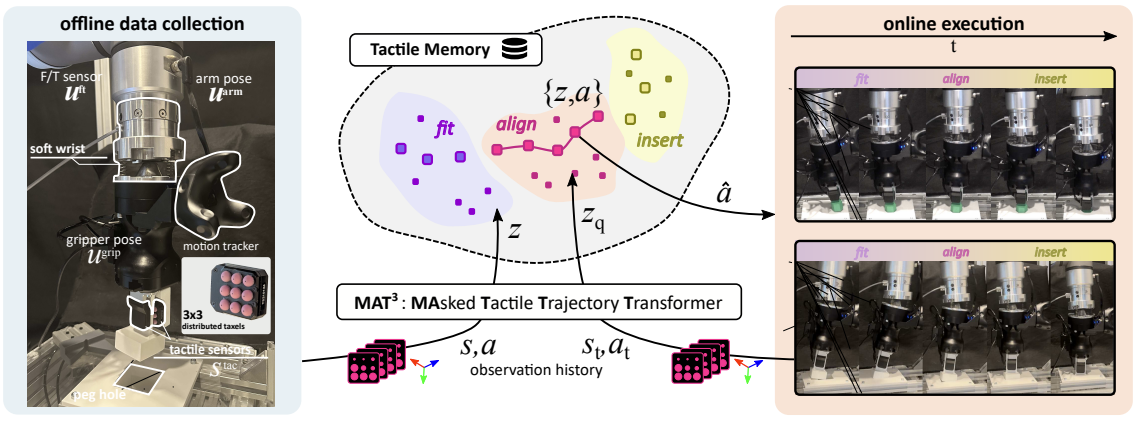
  6. Tactile Memory with Soft Robot: Robust Object Insertion via Masked Encoding and Soft Wrist
    Tatsuya Kamijo, Mai Nishimura, Nodoka Shibasaki, Jeremy Siburian, Cristian C. Beltran-Hernandez, and 1 more author
    IEEE Robotics and Automation Letters, 2026
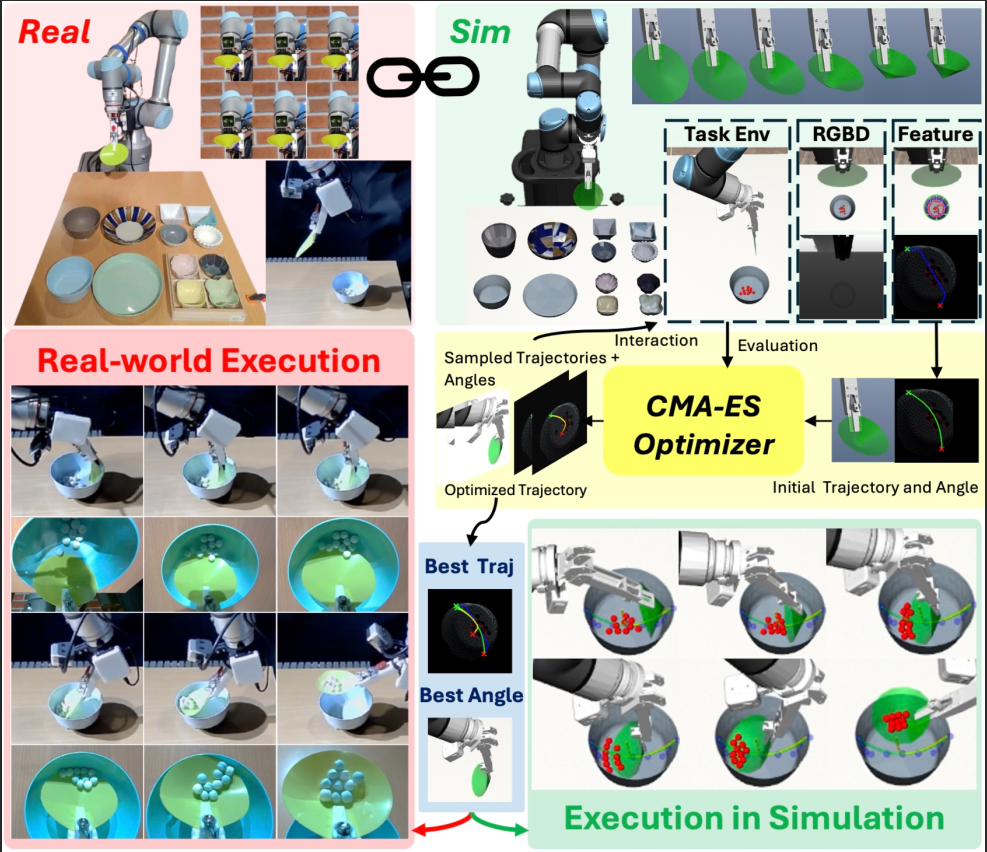
  7. Simulation-Driven Evolutionary Motion Parameterization for Contact-Rich Granular Scooping with a Soft Conical Robotic Hand
    Yongliang Wang, Cristian C. Beltran-Hernandez, Tomoya Takahashi, and Masashi Hamaya
    In IEEE International Conference on Robotics and Automation (ICRA), 2026
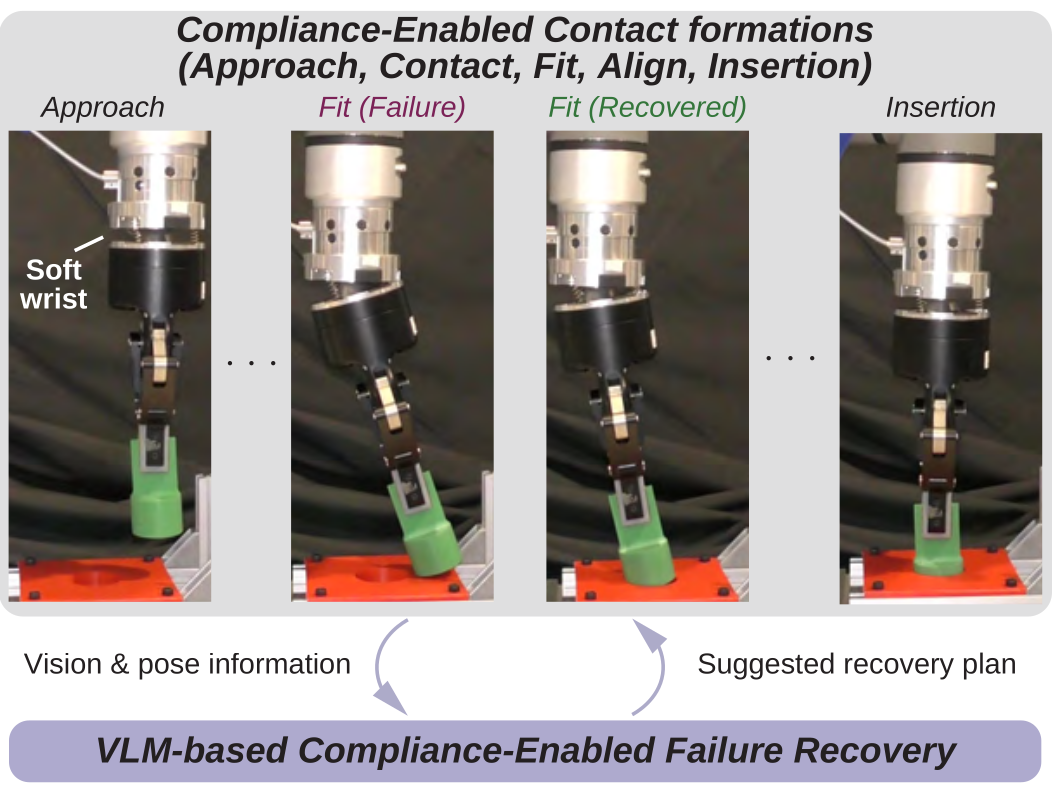
  8. Robust and Resilient Soft Robotic Object Insertion with Compliance-Enabled Contact Formation and Failure Recovery
    Mimo Shirasaka, Cristian C. Beltran-Hernandez, Masashi Hamaya, and Yoshitaka Ushiku
    In IEEE International Conference on Robotics and Automation (ICRA), 2026